Research Projects
Marut Flight Control Unit
Marut FCU is a student-built, open-source flight control unit developed with the explicit goal of supporting quadcopter, fixed-wing, and VTOL platforms under one repository and one evolving firmware architecture.
The project is built around STM32F4 targets, STM32CubeIDE, CMSIS-RTOS v2 on FreeRTOS, and a handwritten control and telemetry stack that remains readable enough for contributors to extend across avionics, firmware, and hardware domains.
What makes it distinctive is not only the tri-mode ambition, but the decision to keep the hardware, firmware structure, build artifacts, and engineering workflow visible in-repo rather than hiding them behind opaque tooling.
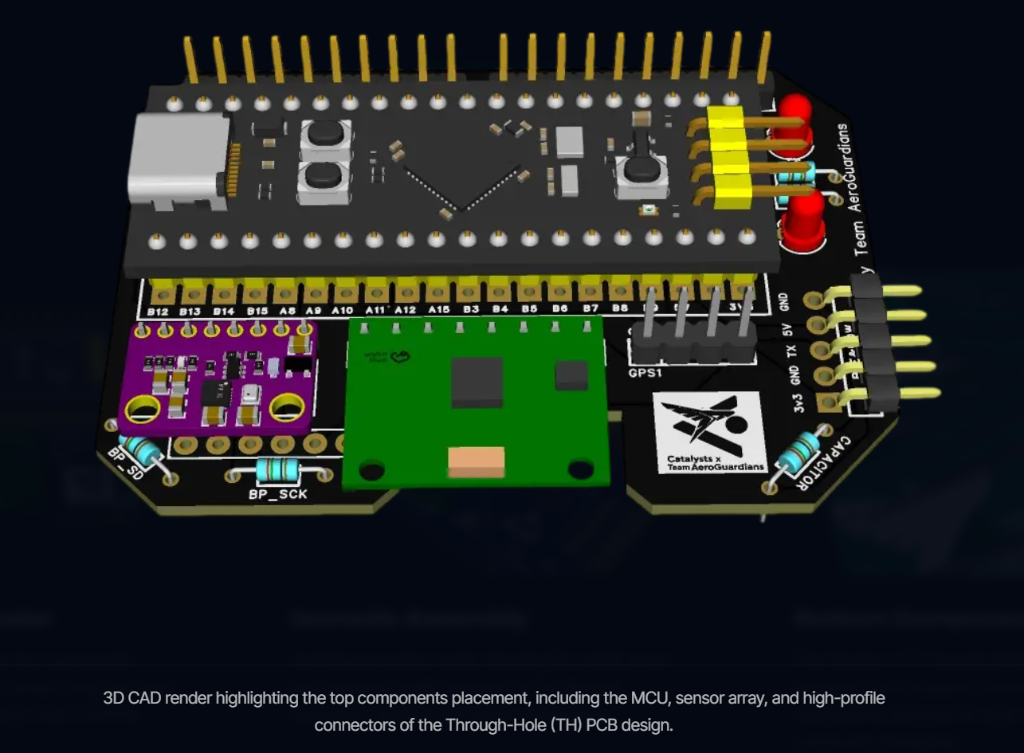
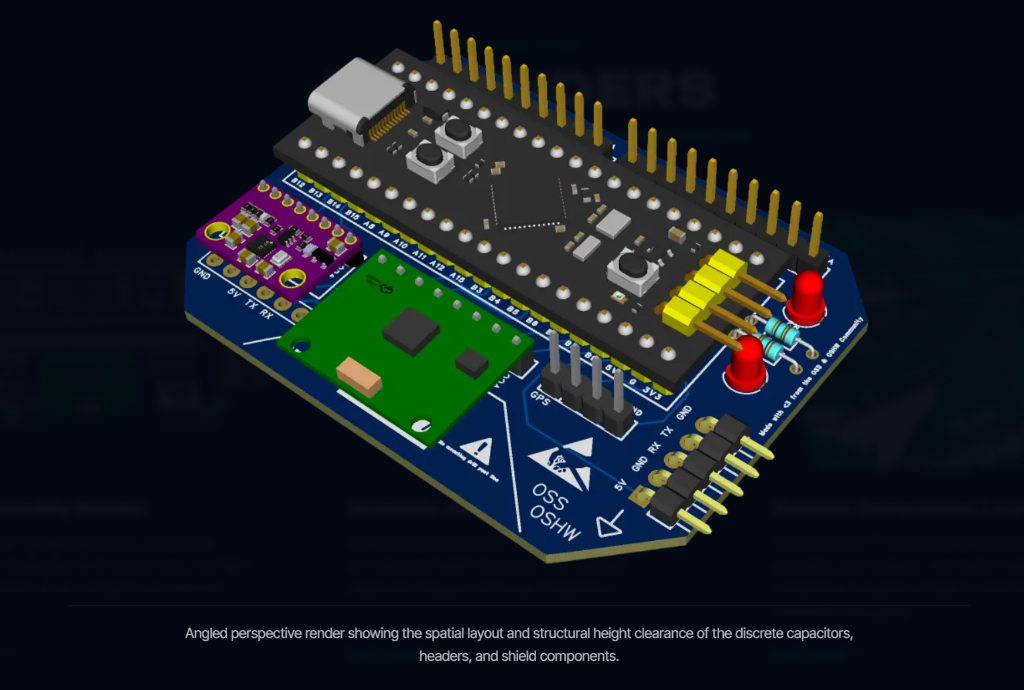
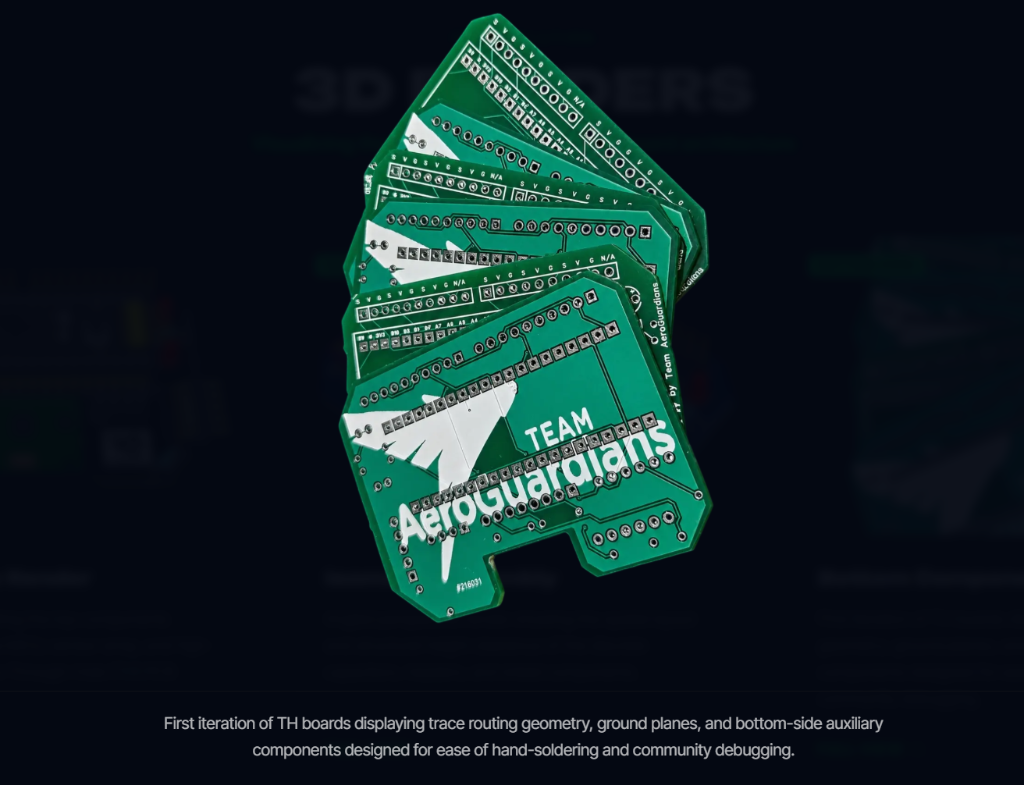
The repository already contains active integrated FCU targets, isolated mode-validation targets, and open PCB/composite scaffolding, while some fixed-wing and VTOL paths remain explicitly marked as pending hardware validation. It should be read as real embedded systems work under active development, not as a finished flight-certified stack.